Closed-Loop Cavity Pressure Control Implementation in Micro-Injection Moulding
Closed-loop cavity pressure control stabilizes micro-injection molding by compensating for viscosity shifts and holding part dimensions within micron tolerances.
Sensor
Direct and Indirect Transducer Architectures in Sub-Gram Cavities
Micro-injection moulding involves shot masses below 0.1 grams and runner diameters under 0.8 millimetres ~ scales where conventional pressure sensors are simply too bulky and sluggish to work. Direct piezoelectric transducers put a quartz sensing element in flush contact with the melt pool inside the cavity. Indirect setups drop a piezoelectric load button behind an ejector pin instead, registering force passed through the pin column.
In micro-cavities, however, pin friction, thermal growth in slender cores, and slight alignment errors skew indirect signals significantly. Direct transducers eliminate those transmission losses, though their smallest commercial face diameters of 1.0 millimetres can easily eclipse the micro-feature itself.
Accurate micro-cavity pressure measurement is largely a fight against signal attenuation and thermal shock. As advancing polymer hits a direct transducer diaphragm, sudden localized heat transfer causes the sensor housing to expand momentarily, registering a false negative dip termed thermal drift. Indirect sensors sidestep that direct heat transfer, but pin binding in micro-drilled sleeve holes introduces hysteresis that frequently exceeds fifteen percent of peak cavity pressure.
Choosing between the two comes down to cavity geometry, tool layout, and how much shear the melt can tolerate near the sensor face.
Direct pressure transducers require mounting pocket perpendicularity within 0.005 millimetres to prevent signal degradation caused by diaphragm pre-stress.
Dynamic response differs sharply across indirect piezo sensors, direct piezo elements, and silicon piezoresistive devices built for micro-cavities. Baseline operating metrics for these sensors in sub-gram tooling appear below.
| Sensor Category | Front Diameter (mm) | Pressure Range (bar) | Resonant Frequency (kHz) | Thermal Drift Error (%) | Minimum Cavity Surface Area (mm²) |
|---|---|---|---|---|---|
| Direct Piezoelectric | 1.0 to 1.8 | 0 to 2500 | > 180 | < 1.5 | 0.78 |
| Indirect Piezoelectric (Pin Load) | 0.5 to 1.0 (Pin) | 0 to 2000 | > 100 | < 0.5 | 0.20 |
| Direct Micro-Piezoresistive | 0.6 to 0.8 | 0 to 1500 | > 50 | 3.8 | 0.28 |
| Fiber-Optic Fabry-Perot | 0.5 to 0.8 | 0 to 2000 | > 120 | < 1.0 | 0.20 |
Charge Amplification and Signal-to-Noise Ratio Optimization
Piezoelectric crystals produce high-impedance electrical charges measured in picocoulombs per bar. Because micro-moulding sensors have such minute contact areas, output is tiny ~ frequently under 0.5 picocoulombs per bar. Long coaxial leads to the charge amplifier pick up stray electromagnetic interference from heater bands, servo drives, and linear encoders, which can drown out the true cavity pressure signal early in the fill.
Mounting the amplifier within two metres of the mould plate cuts that attenuation, preserving the signal-to-noise ratio needed for automated process control.
Digital filtering in the press controller cleans up the trace, but heavy filtering creates phase delay. At injection speeds of 400 millimetres per second, a three-millisecond delay represents several millimetres of screw travel. Closed-loop systems therefore need sampling rates of at least 10 kilohertz to catch the steep pressure rises typical of thin-wall micro-components.
Tool designers also have to mill dedicated wiring channels into the mould base plates, keeping bend radii wide enough to prevent shielding breaks.
Installing sensors without a proper zero-point calibration shifts the baseline pressure curve, preventing accurate switchover detection.
Peak
Melt Front Arrival Detection and Real-Time Switchover Execution
Process controllers key high-speed data acquisition off the exact instant liquid polymer reaches the sensor diaphragm. In conventional moulding, transfer from velocity to pressure control relies on screw position. That approach falls apart in micro-moulding: total screw travel may be under two millimetres, and screw flight clearances, check-ring leakage, and melt compressibility generate volumetric errors larger than the shot itself.
Switching valve actuation directly from cavity pressure feedback sidesteps these machine errors and adapts to viscosity variations automatically.
Melt viscosity wanders constantly with ambient temperature swings, regrind content, and raw resin lot differences, meaning the melt front hits the sensor at varying points in the cycle. Closed-loop controls follow the pressure curve during injection and transfer to pack the moment a target threshold is reached. Because micro-cavity pressure rise slopes routinely top 10,000 bar per second, the machine controller needs sub-millisecond response loops to avoid blowing flash past parting lines.
Under ISO 20753 specimen preparation conditions, cavity pressure closed-loop control reduces shot-to-shot mass variation below 0.12 percent across long production runs.
Viscosity Compensation Logic and Pressure Integral Calculation
Stable processing requires more than cutting over at a single threshold value. Modern systems calculate the pressure-time integral dynamically across both fill and pack, a metric that tracks part weight, feature replication, and volumetric shrinkage closely. When higher melt temperatures drop resin viscosity, the melt flows faster and sharpens the pressure slope inside the cavity.
Detecting that change allows the controller to back off packing pressure or shorten hold time, holding part mass steady cycle after cycle.
Minor variations in gate land clearance alter flow resistance instantly. Closed-loop control compensates by trimming injection speed before pack pressure kicks in. Using the pressure-time integral as an automated sorting metric lets downstream inspection pick out short shots and sink marks non-destructively.
Conventional position-based transfer cannot react to these rheological shifts, leading to physical dimensional drift over a run.
Profiling the complete pressure drop requires placing sensors near the gate and at the end of the flow path. A sensor at the end of fill confirms complete cavity packing directly, eliminating the need to estimate melt velocity.
Spool
Hydraulic and Servo-Electric Valve Dynamic Response Limitations
Closed-loop control is ultimately constrained by actuator dynamics. Even high-grade servo-electric drive motors and hydraulic proportional spools take finite time to execute controller output. Conventional hydraulic servo-valves operate at frequency responses between 50 and 100 hertz, imposing a 10 to 20 millisecond lag during dynamic adjustments.
Given that micro-cavities fill in 15 to 50 milliseconds, sluggish actuators cannot adjust quickly enough to arrest the pressure spike when melt hits cavity end walls.
Direct-drive ball screws on servo-electric injection units provide tight position control, but rotor inertia still resists sudden velocity adjustments. Linear drive motors eliminate mechanical screw linkages altogether, achieving accelerations above 10 g and reaction times under two milliseconds. Pairing cavity pressure feedback with linear-drive injection provides the precision needed for fine microfluidic features.
Can Dynamic Cavity Pressure Override Screw Position Switchover during Viscosity Drift?
Using cavity pressure to override screw position limits during viscosity shifts helps prevent both flash and short shots. Implementing this priority scheme requires clear limits in the press interface to prevent mechanical damage. Setting up hybrid switchover generally follows an established sequence:
- Establish the physical screw position safety boundary at ninety-eight percent of maximum allowable stroke length.
- Set the primary cavity pressure switchover threshold based on baseline T1 tool trial peak values.
- Configure the press controller to execute velocity-to-pressure switchover on whichever limit triggers first during injection.
- Assign an upper cavity pressure limit trip point to dump injection unit system pressure instantly upon detection of pressure spikes.
- Adjust holding pressure decay curves to match the measured natural cooling rate of the micro-part gate section.
Poor control loop tuning produces sharp pressure oscillations in the cavity. Setting PID gains too high causes the motor to hunt, producing structural stress bands in transparent optical parts that destroy light transmission performance.
Nest
Tool Steel Cavity Machining and Sensor Pocket Geometry
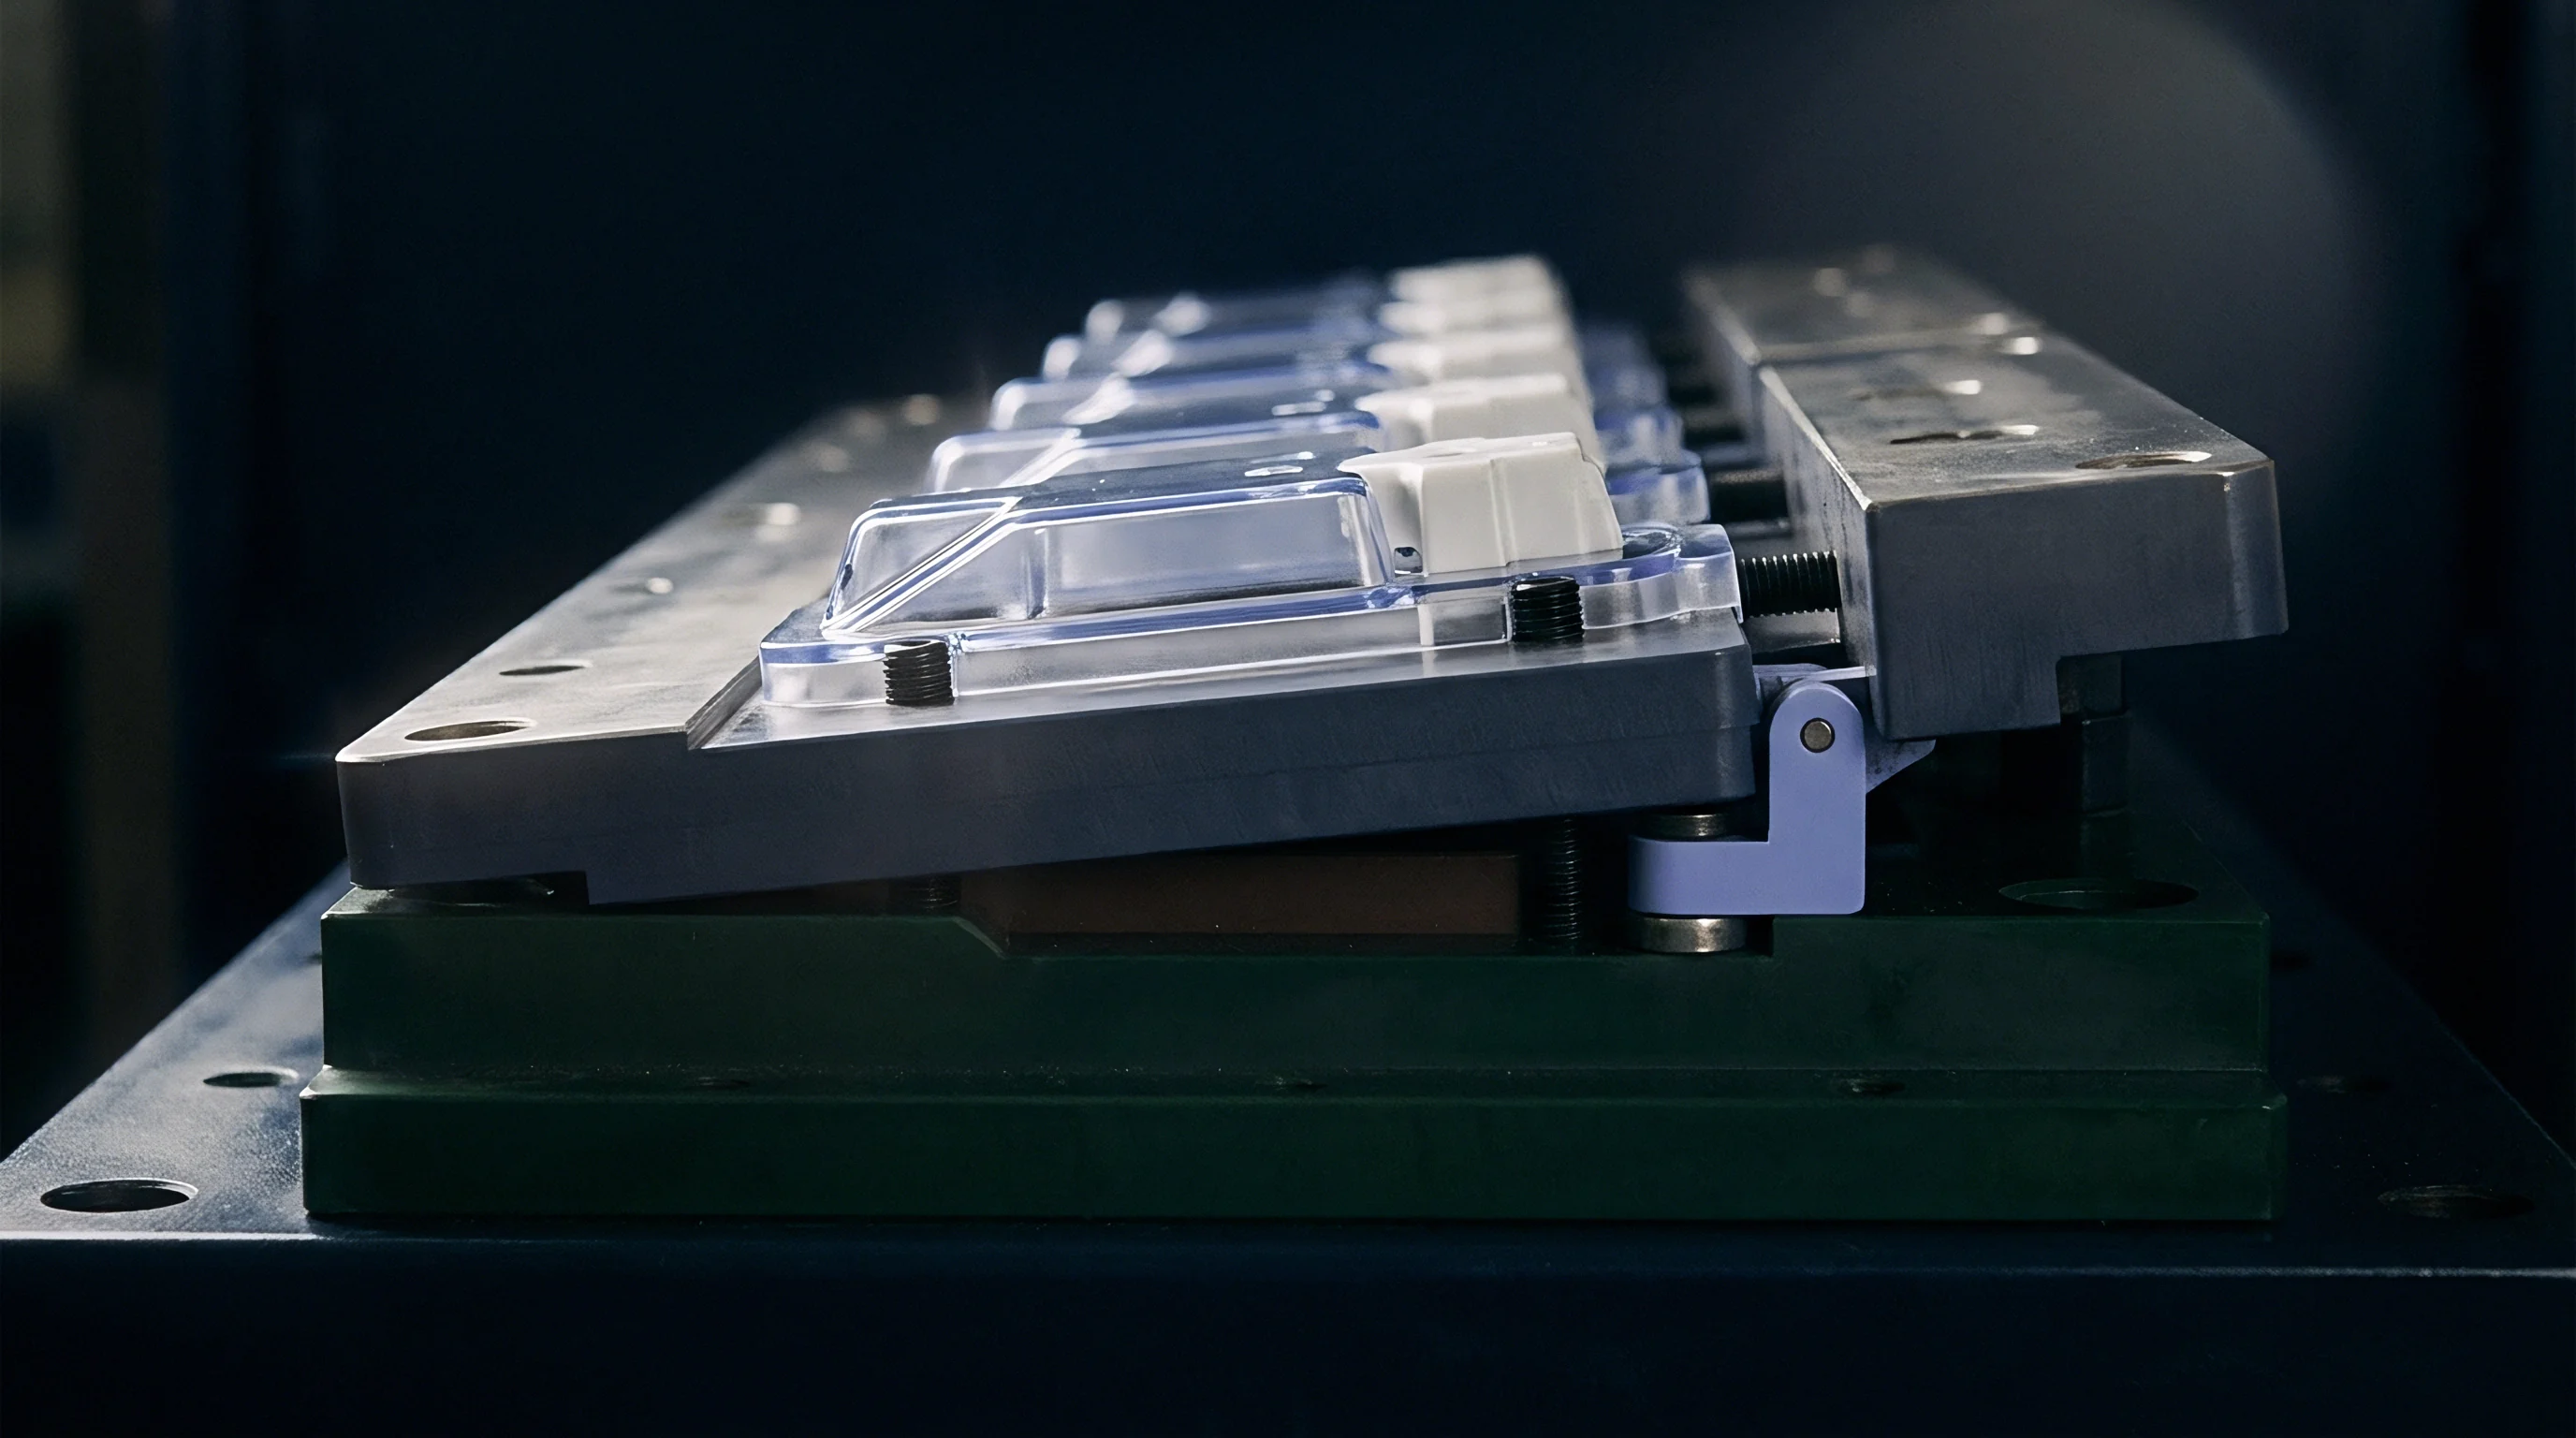
Mould plates require exceptionally tight machining tolerances to house miniature transducers. Sensor bores in hardened tool steels such as stainless 1.2083 or powder-metallurgy CPM 10V demand roundness within 0.002 millimetres. Any bore taper, burr, or misalignment concentrates clamping stress across the transducer housing and shifts its baseline calibration.
Sensor seats must be micro-ground flat within single-micron tolerances to support the back of the sensor flush against the backing plate.
Melt ingress around direct sensor tips is a frequent failure mode in micro-tooling. Diametral clearance between the sensor face and bore must remain under 0.003 millimetres; at micro-moulding pressures, melt easily penetrates gaps wider than 0.005 millimetres, forming a flash ring that solidifies around the tip. This frozen collar pins the sensor diaphragm, dampens pressure transfer, and risks mechanical damage on ejection.
Toolmakers typically turn to sinker EDM or femtosecond laser machining to produce burr-free bores.
Pocket dimensions and clearances must stay within narrow bands to survive cyclic operational loads. The table below lists machining guidelines for sensor installation across common mold tool steel grades.
| Tool Steel Grade | Pocket Bore Tolerance (mm) | Seat Flatness (mm) | Max Sensor Tip Clearance (mm) | Surface Finish (Ra µm) |
|---|---|---|---|---|
| 1.2343 / H13 (52 HRC) | +0.005 / -0.000 | 0.003 | 0.004 | 0.20 |
| 1.2083 / 420 SS (54 HRC) | +0.003 / -0.000 | 0.002 | 0.003 | 0.10 |
| PM-ELMAX (58 HRC) | +0.002 / -0.000 | 0.001 | 0.002 | 0.05 |
| Ampcoloy 940 (Copper Alloy) | +0.008 / -0.000 | 0.004 | 0.005 | 0.40 |
Micro-Ejection Pin Integration and Deflection Mechanics
Indirect systems transfer cavity force via custom ejector pins to load cells seated in the ejector plate. Ejector pins under 0.8 millimetres in diameter bend readily under compressive loading, soaking up force and corrupting amplitude readings. Euler buckling calculations set the maximum permissible length-to-diameter ratio for instrumented pins, requiring guide bushings along virtually their entire length apart from the ejection stroke.
As tooling heats to operating temperature, longitudinal thermal expansion of long pins creates a pre-load against the underlying piezo load cell. Toolmakers mechanical pre-load these sensors during assembly, resetting the charge amplifier to zero only after the mould hits thermal equilibrium. Neglecting this expansion introduces an artificial offset that distorts cavity pressure calculations.
Toolmakers verify several core checks before signing off on micro-moulds with integrated pressure sensors:
- Pocket perpendicularity verification confirms sensor seat alignment relative to the parting plane stays within 0.003 millimetres total indicator reading.
- Pin clearance inspection measures the radial gap between ejector pin bodies and sleeve walls to maintain gaps below 0.003 millimetres.
- Cable pathway mapping ensures internal wiring channels contain rounded chamfers to prevent insulation rubbing during mold opening movements.
- Thermal isolation checking confirms ceramic insulation plates sit between hot runner manifolds and plates housing pressure electronics.
DIN 16742 Molded Part Tolerance Group TG3 applies exclusively when active cavity pressure feedback maintains peak filling pressure consistency within a two percent band.
Tool procurement contracts routinely include specific sensor acceptance criteria, requiring verified pressure signal repeatability over 500 consecutive automatic cycles during T1 qualification.

Tolerance
Process Capability Statistics under Closed-Loop Cavity Control
Holding engineering tolerances on micro-moulded parts requires keeping variation within single-micron limits. Without cavity pressure feedback, process capability (Cpk) frequently drops below 1.00 because minor melt temperature shifts produce disproportionate volumetric shrinkage. Closed-loop cavity pressure control dampens this dispersion, driving long-term Cpk values past 1.67.
Part weight, lens geometry, and micro-gear tooth forms depend directly on peak cavity pressure stability. Because volumetric shrinkage is governed by melt density at gate freeze, stabilizing the pressure integral locks in density and prevents dimensional shift from resin lot variations or hopper temperature swings.
Process capability varies substantially across control methods. The table below tracks statistical process data from 10,000 consecutive shots of a liquid crystal polymer micro-connector housing.
| Control Strategy | Critical Dimension Mean (mm) | Standard Deviation (mm) | Process Capability (Cpk) | Scrap Rate (%) |
|---|---|---|---|---|
| Open-Loop Screw Position | 1.242 | 0.0084 | 0.79 | 4.85 |
| Machine Hydraulic Pressure Closed-Loop | 1.248 | 0.0042 | 1.58 | 0.62 |
| Cavity Pressure Switchover Only | 1.250 | 0.0021 | 3.17 | 0.08 |
| Full Closed-Loop Cavity Pressure Integral Control | 1.251 | 0.0011 | 6.06 | < 0.01 |
Worked Empirical Comparison of Dimensional Variance in Micro-Gears
A production case highlights the practical impact of closed-loop pressure management. Consider a 12-tooth polyoxymethylene micro-gear with a target pitch diameter of 2.500 millimetres and a drawing tolerance of plus or minus 0.008 millimetres under DIN 16742 Grade TG3, run across a 100,000-part production batch over 72 hours.
Under standard position-based switchover, resin viscosity variations of plus or minus seven percent produce pitch diameters spanning 2.486 millimetres to 2.512 millimetres. A standard deviation of 0.0043 millimetres yields a Cpk of 0.62, generating roughly 5,200 non-conforming gears per 100,000-part lot through tooth sink or flash that jams gear trains.
Switching to cavity-pressure transfer and dynamic pack adjustment tightens the distribution considerably. Standard deviation falls to 0.0009 millimetres around a 2.500 millimetres mean, lifting Cpk to 2.96. Rejects fall under ten parts per 100,000, making downstream dimensional sorting unnecessary.
Development work in micro-moulding focuses on pairing closed-loop cavity pressure signals with real-time ultrasonic cavity imaging to address non-isotropic molecular orientation during cooling.
Payout
Tooling Retrofit Capital Expenditure versus Scrap Reduction Arithmetic
Retrofitting cavity pressure sensors into existing micro-tooling involves sensor procurement, EDM pocket machining, charge amplifiers, controller interface cards, and machine software options. For a two-cavity tool, capital outlay generally runs between 14,000 and 18,000 euros including installation labor and initial calibration.
Economic payback comes primarily from scrap reduction and resin savings. Resins such as polyetheretherketone or fluorinated ethylene propylene command 120 to 300 euros per kilogram, and optical sorting of micro-parts adds substantial inspection cost. Cavity pressure monitoring allows automatic part segregation directly at the press, routing out-of-spec shots into scrap bins before packaging.
Weighing direct capital costs against yield gains establishes the payback window for a given production volume. Typical outfitting costs for a micro-moulding cell break down as follows:
- Sensors and signal amplifiers require roughly 6,500 euros in hardware per cavity set.
- Tooling modifications and wiring channels consume 3,000 euros in precision wire EDM and sinker machining labor.
- Machine software integration cards cost 4,500 euros for controller channel enablement and dynamic software unlock keys.
- Calibration standards and initial setup take 1,800 euros for T1 trial press time and baseline force verification.
Sensor Longevity and Replacement Amortisation Schedules
Micro-moulding environments place severe thermal and mechanical loads on pressure transducers. Cyclic injection pressures up to 2500 bar alongside tool temperatures of 180 degrees Celsius cause fatigue over extended runs. Transducers typically deliver two to five million cycles under normal conditions before the quartz element shows charge degradation.
Tooling amortization models require dedicated sensor replacement reserves to maintain capability across multi-year contracts. Sinking 0.002 to 0.005 euros per shot establishes an adequate budget for replacing fatigued transducers, damaged cables, and worn pins without unplanned spending. Incorporating this wear directly into piece-part pricing protects operating margins over the life of high-volume micro-moulding programs.
Multi-cavity tools also complicate the amortization math, as each cavity requires its own sensing channel. Balancing pressure across eight or sixteen sub-gram impressions demands individual feedback channels to tune runner delivery independently.